1. 패키지 생성
– 패키지 이름 : zetabank_robot_control
– zetabank_diffwheeled_robot_control.cpp : motor driver와 serial 통신, twist의 cmd_vel을 전달받아 모터 드라이버 제어(시리얼 통신), 현재 이동거리, 속도, 센서 데이터 퍼블리쉬
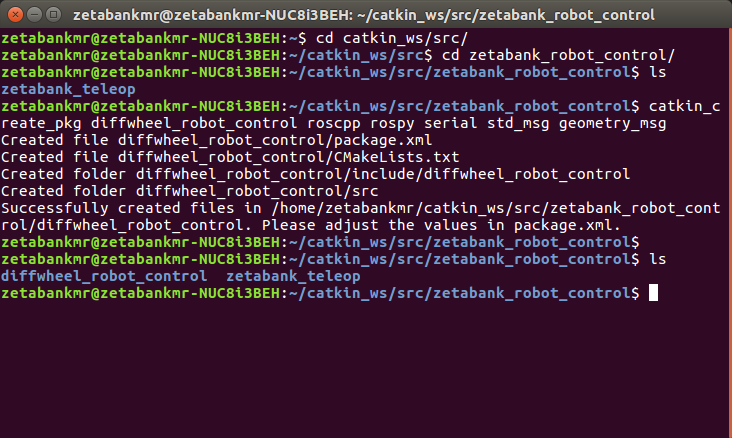
catkin_create_pkg diffwheel_robot_control roscpp rospy serial std_msg geometry_msg
2. 컴파일 환경 구축
먼저 패키지를 생성한 “zetabank_robot_control” 폴더로 이동합니다.
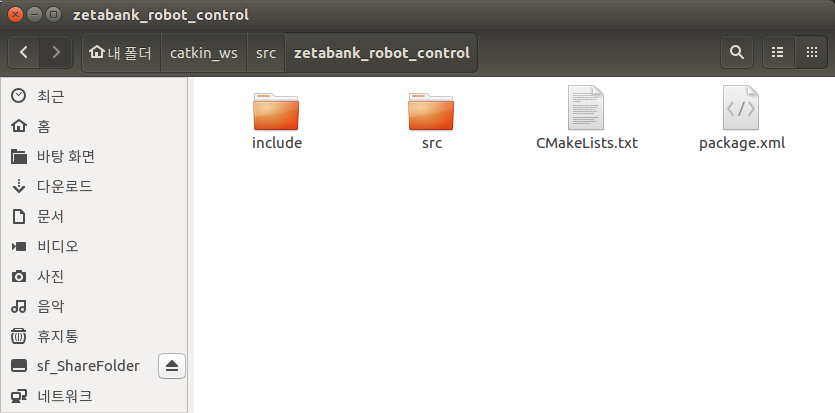
여기서 package.xml 파일과 다음과 같이 수정합니다.
<?xml version=”1.0″?> <package format=”2″> <name>diffwheel_robot_control</name> <version>0.1.0</version> <description>The differential wheel robot control package</description> <author email=”sjyong@humanoidsystem.com”>Seo, Jae Yong</author> <maintainer email=”sjyong@humanoidsystem.com”>Seo, Jae Yong</maintainer> <license>BSD</license> <buildtool_depend>catkin</buildtool_depend> <build_depend>geometry_msgs</build_depend> <build_depend>roscpp</build_depend> <build_depend>rospy</build_depend> <build_depend>serial</build_depend> <build_depend>std_msgs</build_depend> <build_export_depend>geometry_msgs</build_export_depend> <build_export_depend>roscpp</build_export_depend> <build_export_depend>rospy</build_export_depend> <build_export_depend>serial</build_export_depend> <build_export_depend>std_msgs</build_export_depend> <exec_depend>geometry_msgs</exec_depend> <exec_depend>roscpp</exec_depend> <exec_depend>rospy</exec_depend> <exec_depend>serial</exec_depend> <exec_depend>std_msgs</exec_depend> </package>
CMakeLists.txt 파일을 아래의 내용으로 수정합니다.
cmake_minimum_required(VERSION 2.8.3)
project(diffwheel_robot_control)

find_package(catkin REQUIRED COMPONENTS
	geometry_msgs
	roscpp
	rospy
	serial
	std_msgs
	tf
)

catkin_package(
CATKIN_DEPENDS
	geometry_msgs
	roscpp
	rospy
	serial
	std_msgs
	tf
)

include_directories(
# include
  ${catkin_INCLUDE_DIRS}
)

add_executable(${PROJECT_NAME}_node src/diffwheel_robot_control.cpp)

target_link_libraries(${PROJECT_NAME}_node
   ${catkin_LIBRARIES}
)

#############
## Install ##
#############

## Mark executables and/or libraries for installation
install(TARGETS diffwheel_robot_control
  RUNTIME DESTINATION ${CATKIN_PACKAGE_BIN_DESTINATION}
)

## Mark all other useful stuff for installation
install(DIRECTORY launch
        DESTINATION ${CATKIN_PACKAGE_SHARE_DESTINATION}
)
diffwheel_robot_control_node.cpp 파일을 아래와 같이 작성합니다.
#include <ros/ros.h>
#include <ros/time.h>

#include <serial/serial.h>

#include <std_msgs/String.h>
#include <std_msgs/Empty.h>
#include <std_msgs/Bool.h>
#include <std_msgs/Int32.h>
#include <std_msgs/Float64.h>

#include <geometry_msgs/Vector3.h>
#include <geometry_msgs/Twist.h>
#include <tf/tf.h>

#define LEFT                             0
#define RIGHT                            1

#define LINEAR                              0
#define ANGULAR                             1

#define MAX_LINEAR_VELOCITY                2.0             // m/s   (BURGER : 0.22, WAFFLE : 0.25)
#define MAX_ANGULAR_VELOCITY               2.0             // rad/s (BURGER : 2.84, WAFFLE : 1.82)
#define LINEAR_X_MAX_VELOCITY              2.0

#define PI  3.1415926535897932384626433832795
#define MATH_RAD2DEG    57.2957795f
#define MATH_DEG2RAD    0.0174532f

#define WHEEL_NUM                           2
#define WHEEL_RADIUS                       0.0812          // meter
#define WHEEL_SEPARATION                   0.360          // meter (BURGER : 0.160, WAFFLE : 0.287, zetabank : 0.360)
#define GEARRATIO                           26
#define ENCODER_MIN                         -2147483648     // raw
#define ENCODER_MAX                         2147483648      // raw
#define VELOCITY_UNIT                       2
#define DISTORPM                             (60.0*GEARRATIO)/(2*PI*WHEEL_RADIUS)
#define CONTROL_MOTOR_SPEED_PERIOD         1000/50        //50hz. 20ms


float goal_velocity[VELOCITY_UNIT] = {0.0, 0.0};
float goal_velocity_from_cmd[VELOCITY_UNIT] = {0.0, 0.0};
bool teleop_flg = false;
float pre_velocity[VELOCITY_UNIT] = {0.0, 0.0};
unsigned int vel_same_cnt = 0;
unsigned int vel_total_same_cnt = 0;

uint32_t tTime[5];
ros::Time current_time;
uint64_t current_offset;
float prev_wheel_velocity_cmd[2];

std_msgs::String motorctrl_str;

void write_callback(const std_msgs::String::ConstPtr& msg);
// Callback function prototypes
void commandVelocityCallback(const geometry_msgs::Twist& cmd_vel_msg);
float constrain(float value, float min, float max);
void MotorDriver_Enable();
void MotorDriver_Disable();
void MotorDriver_SetMode();
void MotorDriver_SetSpeed(int leftSpeed, int rightSpeed);
void init_MotorController();
bool controlMotor(float * value);
void updateGoalVelocity(void);
void check_vel_safety(float *velocity);
ros::Time rosNow();


serial::Serial serial_comm;


int main (int argc, char** argv){
    ros::init(argc, argv, "zetabank_robot_control_node");

    ros::NodeHandle nh;
    //nh.iniNode();

    ros::Subscriber write_sub = nh.subscribe("write", 1000, write_callback);
    ros::Publisher read_pub = nh.advertise<std_msgs::String>("read", 1000);

    ros::NodeHandle node_obj;
    ros::Subscriber cmdvel_subscriber = node_obj.subscribe("cmd_vel",10,commandVelocityCallback);
    //ros::spin();

    try
    {
        serial_comm.setPort("/dev/ttyUSB0");
        serial_comm.setBaudrate(9600);
        serial::Timeout to = serial::Timeout::simpleTimeout(1000);
        serial_comm.setTimeout(to);
        serial_comm.open();
    }
    catch (serial::IOException& e)
    {
        ROS_ERROR_STREAM("Unable to open port ");
        return -1;
    }

    if(serial_comm.isOpen()){
        ROS_INFO_STREAM("Serial Port initialized");

        std_msgs::String test_string;
        test_string.data = "Send test string!!!";
        serial_comm.write(test_string.data);
    } else {
        return -1;
    }

    ros::Rate loop_rate(10);
    uint32_t t;
    tTime[0] = 0;
    prev_wheel_velocity_cmd[0] = 0.0f;
    prev_wheel_velocity_cmd[1] = 0.0f;

    init_MotorController();

    ROS_INFO_STREAM("Ready....");

    while(ros::ok()){

        t = ros::Time::now().toNSec();

        current_offset = ros::Time::now().toNSec();
        current_time   = ros::Time::now();

        if((t- tTime[0]) >= (CONTROL_MOTOR_SPEED_PERIOD)) {
            updateGoalVelocity();
            //check_vel_safety(goal_velocity);
            controlMotor(goal_velocity);
        }

        ros::spinOnce();

        if(serial_comm.available()){
            ROS_INFO_STREAM("Reading from serial port");
            std_msgs::String result;
            result.data = serial_comm.read(serial_comm.available());
            ROS_INFO_STREAM("Read: " << result.data);
            read_pub.publish(result);
        }
        loop_rate.sleep();

    }

    MotorDriver_Disable();
}

void write_callback(const std_msgs::String::ConstPtr& msg){
    ROS_INFO_STREAM("Writing to serial port" << msg->data);
    serial_comm.write(msg->data);
}

float constrain(float value, float min, float max)
{
    if(value > max) return max;
    if(value < min) return min;
    return value;
}

/*******************************************************************************
  Callback function for cmd_vel msg
*******************************************************************************/
void commandVelocityCallback(const geometry_msgs::Twist & cmd_vel_msg)
{
    goal_velocity_from_cmd[LINEAR]  = cmd_vel_msg.linear.x;
    goal_velocity_from_cmd[ANGULAR] = cmd_vel_msg.angular.z;

    goal_velocity_from_cmd[LINEAR]  = constrain(
                                      goal_velocity_from_cmd[LINEAR],
                                      (-1) * MAX_LINEAR_VELOCITY,
                                      MAX_LINEAR_VELOCITY
                                    );
    goal_velocity_from_cmd[ANGULAR] = constrain(
                                      goal_velocity_from_cmd[ANGULAR],
                                      (-1) * MAX_ANGULAR_VELOCITY,
                                      MAX_ANGULAR_VELOCITY
                                    );
}

void MotorDriver_Enable()
{
    motorctrl_str.data = "PE0001;";

    if(serial_comm.isOpen()){
        serial_comm.write(motorctrl_str.data);
    }
}

void MotorDriver_Disable()
{
    motorctrl_str.data = "PD0001;";

    if(serial_comm.isOpen()){
        serial_comm.write(motorctrl_str.data);
    }
}

void MotorDriver_SetMode()
{
    motorctrl_str.data = "SM0505;";

    if(serial_comm.isOpen()){
        serial_comm.write(motorctrl_str.data);
    }
}

void MotorDriver_SetSpeed(int leftSpeed, int rightSpeed)
{
    std::stringstream ss;

    ss << "SV" << leftSpeed << "," << rightSpeed;
    motorctrl_str.data = ss.str();

    if(serial_comm.isOpen()){
        serial_comm.write(motorctrl_str.data);
        //if(leftspeed)
        ROS_INFO_STREAM("Set Speed (" << leftSpeed << "," << rightSpeed << ")");
    }
}

void init_MotorController()
{
    ros::Rate idle(10000);

    MotorDriver_Enable();

    idle.sleep();

    MotorDriver_SetMode();

    idle.sleep();

    ROS_INFO_STREAM("Initialize motor driver");
}

bool controlMotor(float * value)
{

    float wheel_velocity_cmd[2];

    wheel_velocity_cmd[LEFT]  = value[LINEAR] - (value[ANGULAR] * WHEEL_SEPARATION / 2.0f);
    wheel_velocity_cmd[RIGHT] = value[LINEAR] + (value[ANGULAR] * WHEEL_SEPARATION / 2.0f);

    wheel_velocity_cmd[LEFT]  = constrain(wheel_velocity_cmd[LEFT], -LINEAR_X_MAX_VELOCITY, LINEAR_X_MAX_VELOCITY);
    wheel_velocity_cmd[RIGHT] = constrain(wheel_velocity_cmd[RIGHT], -LINEAR_X_MAX_VELOCITY, LINEAR_X_MAX_VELOCITY);

    wheel_velocity_cmd[LEFT] = -1.0*wheel_velocity_cmd[LEFT]*DISTORPM;
    wheel_velocity_cmd[RIGHT] = 1.0*wheel_velocity_cmd[RIGHT]*DISTORPM;

    if((prev_wheel_velocity_cmd[LEFT] != wheel_velocity_cmd[LEFT]) || (prev_wheel_velocity_cmd[RIGHT] != wheel_velocity_cmd[RIGHT])) {
        MotorDriver_SetSpeed((int)wheel_velocity_cmd[LEFT], (int)wheel_velocity_cmd[RIGHT]);

        prev_wheel_velocity_cmd[LEFT] = wheel_velocity_cmd[LEFT];
        prev_wheel_velocity_cmd[RIGHT] = wheel_velocity_cmd[RIGHT];
    }

    return true;
}

void updateGoalVelocity(void)
{
    // Recieve goal velocity through ros messages
    goal_velocity[LINEAR]  = goal_velocity_from_cmd[LINEAR];
    goal_velocity[ANGULAR] = goal_velocity_from_cmd[ANGULAR];
}

void check_vel_safety(float *velocity)
{
    if(teleop_flg == true)
    {
        return ;
    }

    vel_total_same_cnt++;

    if( (pre_velocity[LINEAR] == velocity[LINEAR]) &&  (pre_velocity[ANGULAR] == velocity[ANGULAR]) )
    {
        vel_same_cnt++;
    }

    if(vel_same_cnt >= 500 && vel_total_same_cnt >= 500)
    {
        char log_msg[10];
        goal_velocity_from_cmd[LINEAR] = 0;
        goal_velocity_from_cmd[ANGULAR] = 0;

        MotorDriver_SetSpeed(0, 0);

       // sprintf(log_msg, "Same_vel");
       // nh.loginfo(log_msg);
        vel_same_cnt = 0;
    }
    else if(vel_total_same_cnt >= 500)
    {
        //For clear the case of having same velocity
        vel_same_cnt = 0;
        vel_total_same_cnt = 0;
    }

    pre_velocity[LINEAR] = velocity[LINEAR];
    pre_velocity[ANGULAR] = velocity[ANGULAR];

}

ros::Time rosNow()
{
    uint32_t sec, nsec;


    uint64_t _micros = ros::Time::now().toNSec() - current_offset;


    sec  = (uint32_t)(_micros / 1000000) + current_time.sec;
    nsec = (uint32_t)(_micros % 1000000) + 1000 * (current_time.nsec / 1000);

    if (nsec >= 1e9) {
    sec++,
        nsec--;
    }
    return ros::Time(sec, nsec);
 }
3. 패키지를 컴파일 합니다.
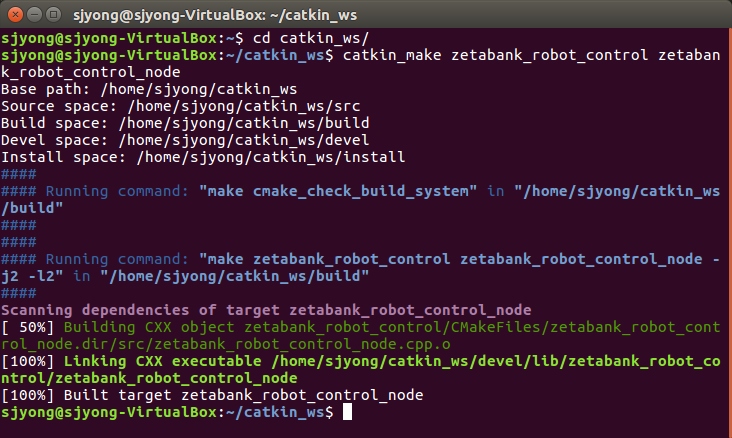
catkin_make diffwheel_robot_control diffwheel_robot_control_node
4. 패키지를 실행합니다.
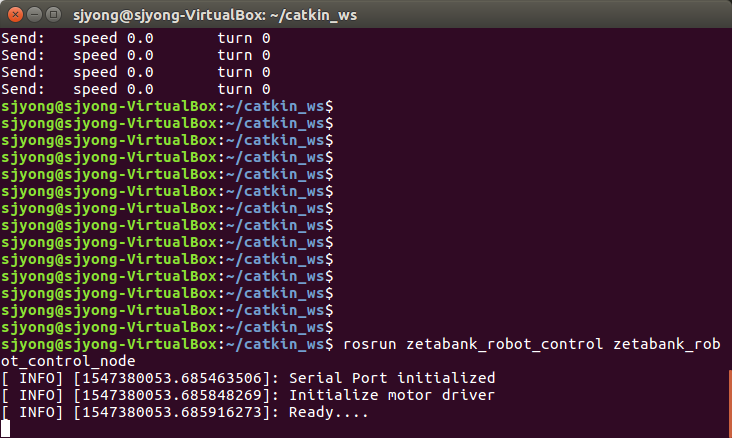
rosrun diffwheel_robot_control diffwheel_robot_control_node